A specialist website by Oxford Industrial Automation

UK robot & vision integration · 01865 416830

High-speed handling

Delta robot vision sorting systems

Delta and parallel robots are designed for rapid overhead handling of suitable products across a conveyor work area. Camera detection, product tracking, grip time, robot scheduling and downstream placement set the achievable output.

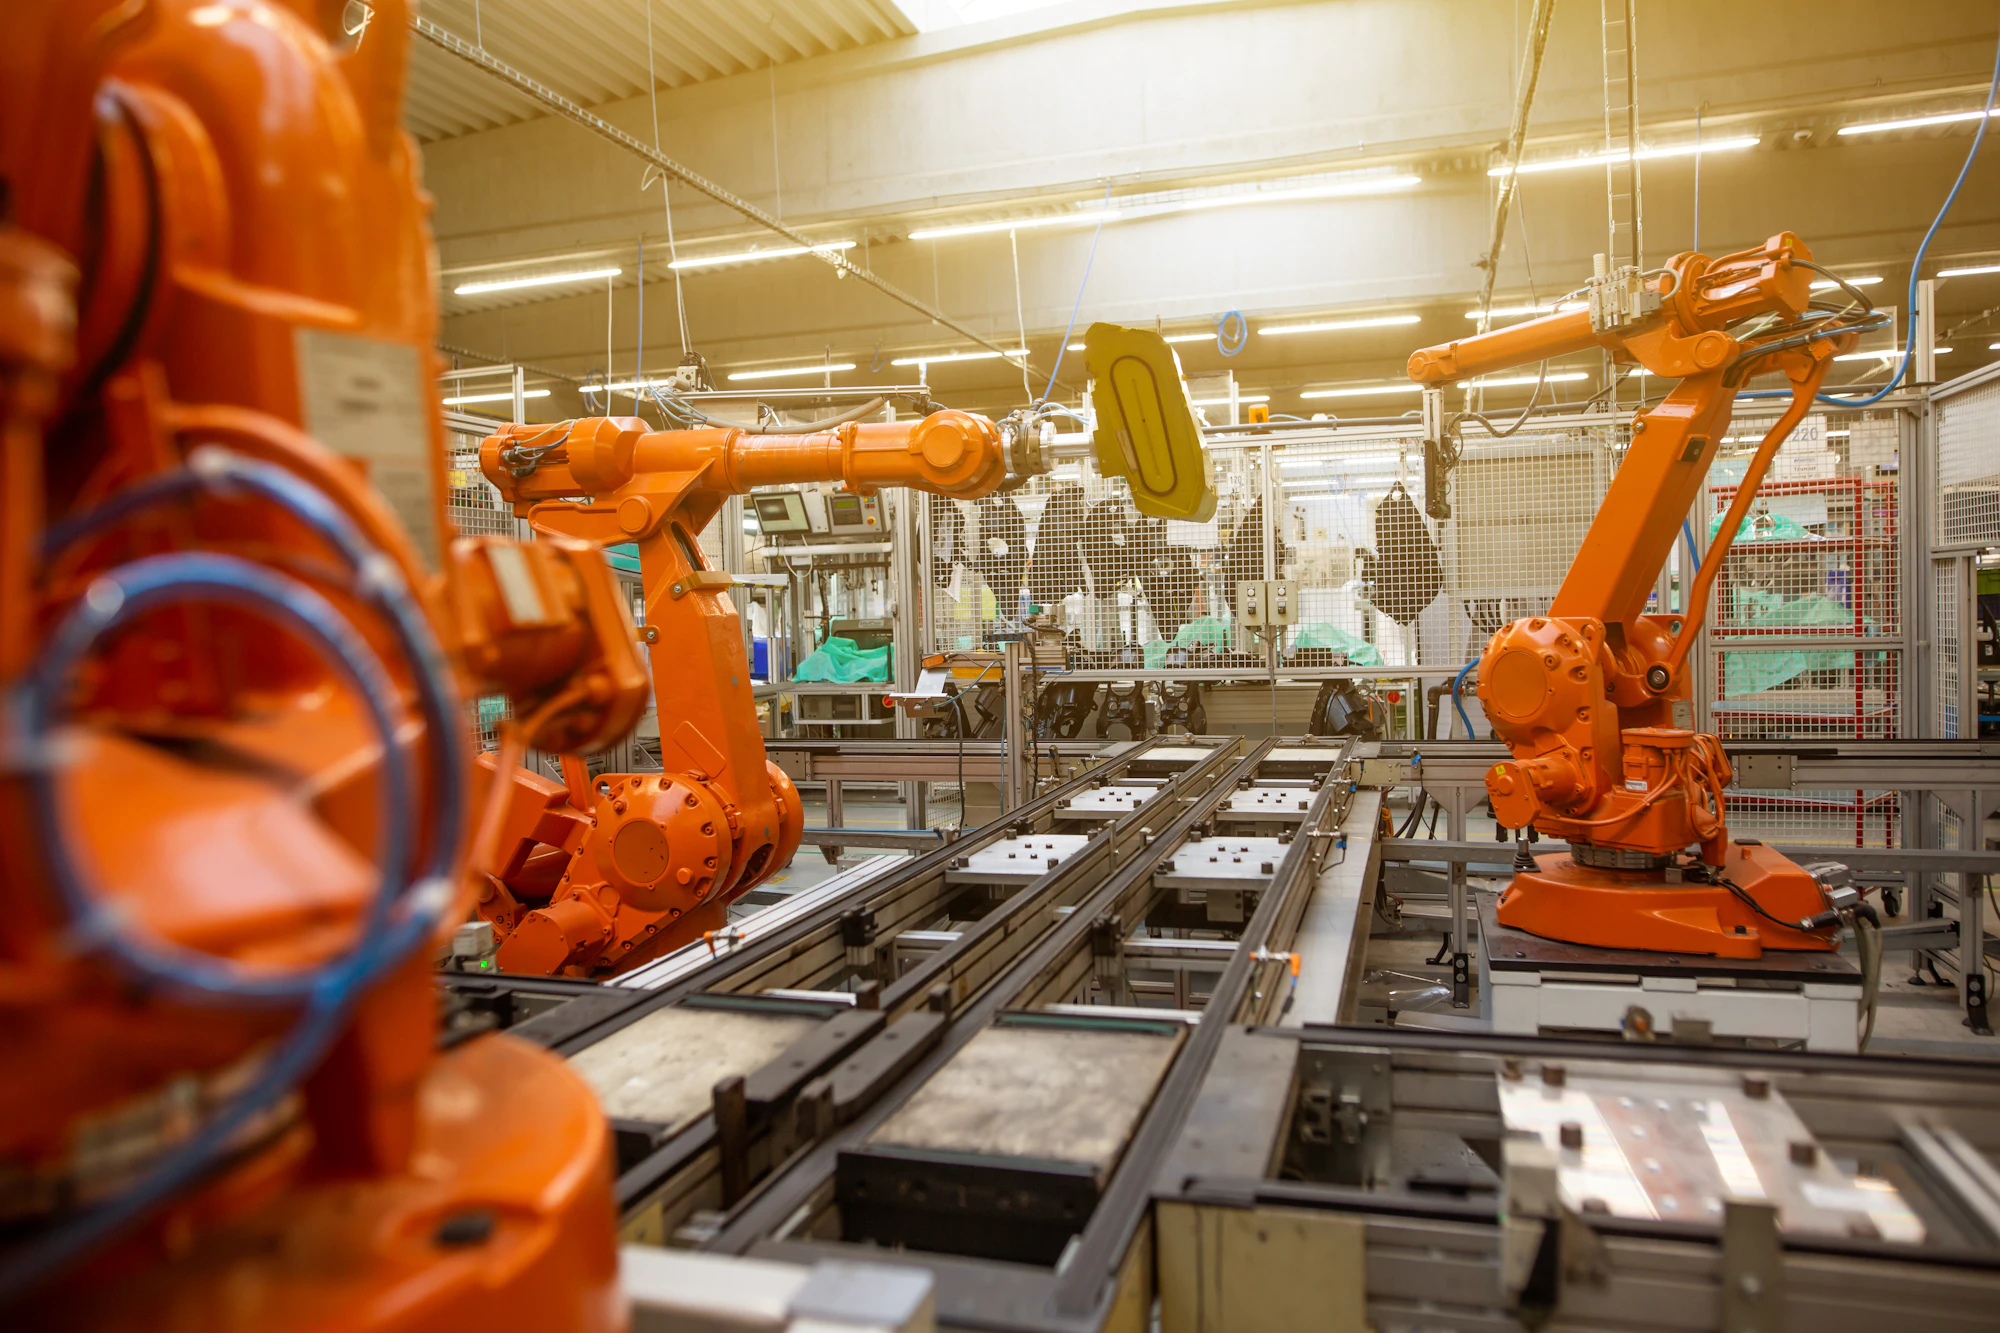
Orange industrial robot arms beside production equipment.
StrengthRapid repetitive picks over a defined overhead workspace
ProductLight to moderate moving payloads with reliable gripping
ScaleSingle or multiple robots sharing a tracked product stream
01 / Engineering focus

Output is a complete-cycle calculation

Published robot cycle figures do not include image capture, product spacing, travel distance, gripping, placement, missed targets or product changeover. We model the real sequence and expected product distribution.

  • High-speed food and packaged-product handling
  • Random pick and ordered placement
  • Grade, type or quality-based sorting
  • Multi-robot line balancing
  • Rotation and controlled product orientation where supported
02 / Engineering focus

A stable pick is essential at speed

Vacuum response, product porosity, surface contamination, tool compliance and product acceleration all affect successful handling. Tool trials form part of the application proof.

  • Fast vacuum generation and release
  • Multi-zone or format tooling
  • Grip confirmation and mis-pick logic
  • Hygienic or washdown considerations where applicable

System sequence

Engineer the complete decision loop.

Every stage is tested against the product, timing, interfaces and agreed response.

01

Present

Create sufficient separation and a visible gripping area.

02

Detect

Locate and classify each candidate within the image area.

03

Allocate

Schedule reachable picks across the robot capacity.

04

Place

Release accurately into the required pack, lane or pattern.

Typical applications

Where this capability can fit.

Final suitability and performance are confirmed only after review of the complete production application.

High-speed conveyor picking
Product grading
Pack and tray loading
Multi-robot sorting
Random-to-ordered handling
Recipe-controlled formats

Application questions

What manufacturers ask.

These answers provide a starting point. Product trials and line data determine the project specification.

How fast can a delta robot sorting system run?

The practical rate depends on pick distance, product mass, grip time, placement pattern, product distribution and the proportion of usable targets. We confirm output from the complete application cycle.

Can delta robots handle randomly orientated products?

Yes where vision can locate a usable pick point and the robot or tooling can create the required final orientation within the cycle.

When are several delta robots required?

Multiple robots may be used when one robot cannot cover the required throughput, pick window or destination mix. Product allocation and downstream capacity must be balanced across the line.

Start with the production task

Show us what the system needs to see and move.

Use the project brief form, or email product photos or video with the target output, current layout and required decision. We will define the next technical step.

Project brief